Works / An evolving body of researchContact → movement → intelligence

From first contact
to a complete body.

Our work begins at the hand and follows the forces inward. Each study opens a different question about how a robot moves, feels and can be put back to work.

Begin with the hand
Flagship research / The insilico hand

Make dexterity
repairable.

Dimensioned CAD · Passive mechanics

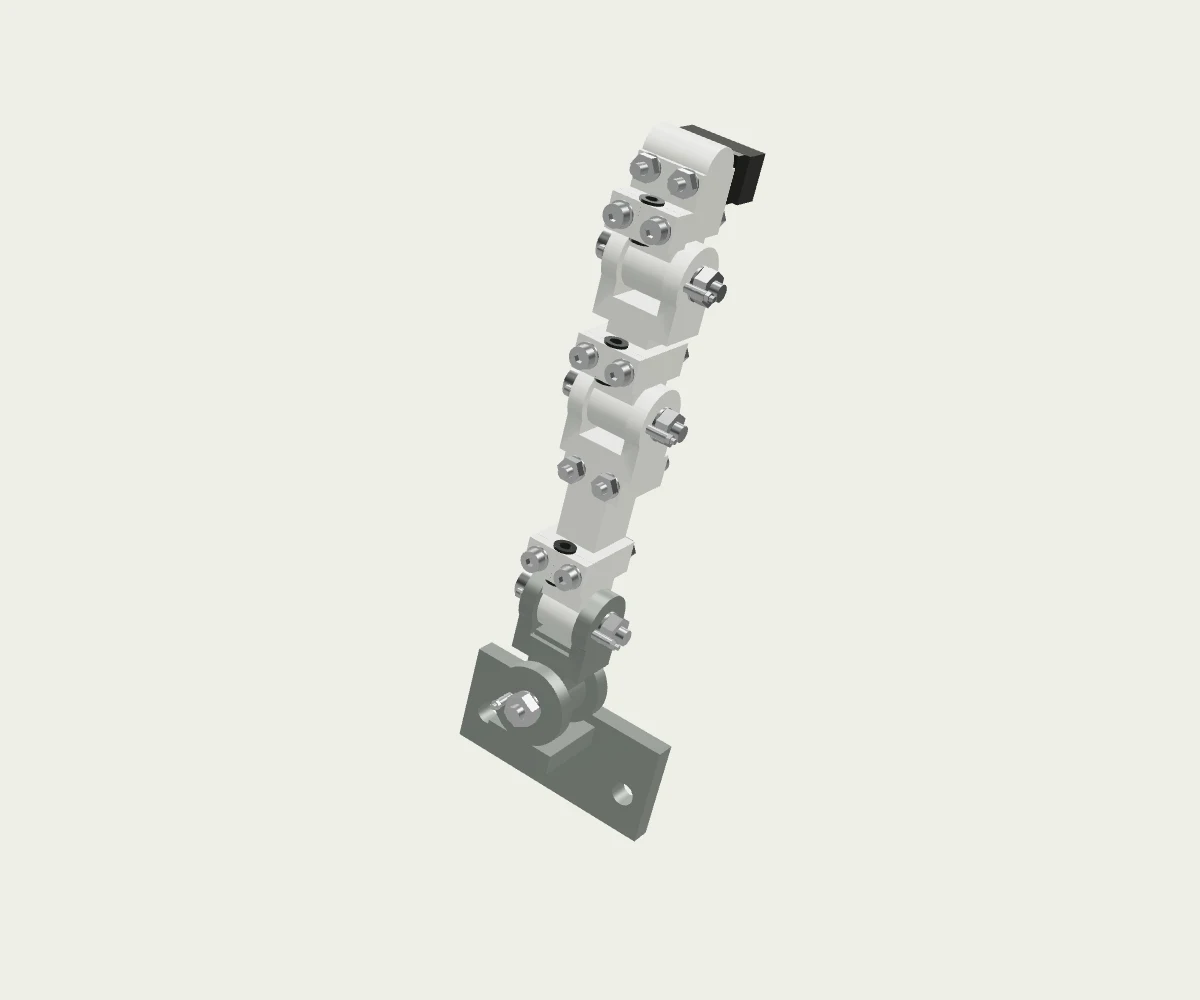
A human-shaped hand is the ambition. This first engineering checkpoint opens up one finger: its joints, stops, contact pad and replaceable guides.

HAND-S0001 / mechanics-03Interactive 3D / The index-finger checkpoint
The current passive index-finger CAD specimen, with its retained pivots, joint stops, separate contact pad and guide components. The browser model follows the frozen engineering assembly.

The index-finger checkpoint · Three-dimensional study

Drag to orbit · Shift + drag to pan · + / − zoom

An idea becomes a set of interfaces.

Inspect the current geometry, then open the exploded view to see how the parts relate. The full hand is being developed from this bounded mechanical checkpoint.

CAD checkpoint, not a working hand. Actuation, sensing and continuous tendon routing remain to be engineered and tested. Exploded spacing aids inspection, not assembly.

Inside The index-finger checkpoint
Retained joints
Four passive geometric axes define this index-finger specimen.
Contact pad
A separate pad keeps the contact surface distinct from the finger structure.
Wear components
Replaceable guides and liners expose the parts that need to remain accessible.
Stops and fasteners
Retained pivots and finite travel limits belong to the assembly, not just the silhouette.
insilico / inspectionThe index-finger checkpoint
Inside the hand programmeArchitecture, geometry & next experiment
Open investigations

Two ways to rethink
the structure underneath.

Geometric concept / Moving tendon anchors

Counterform

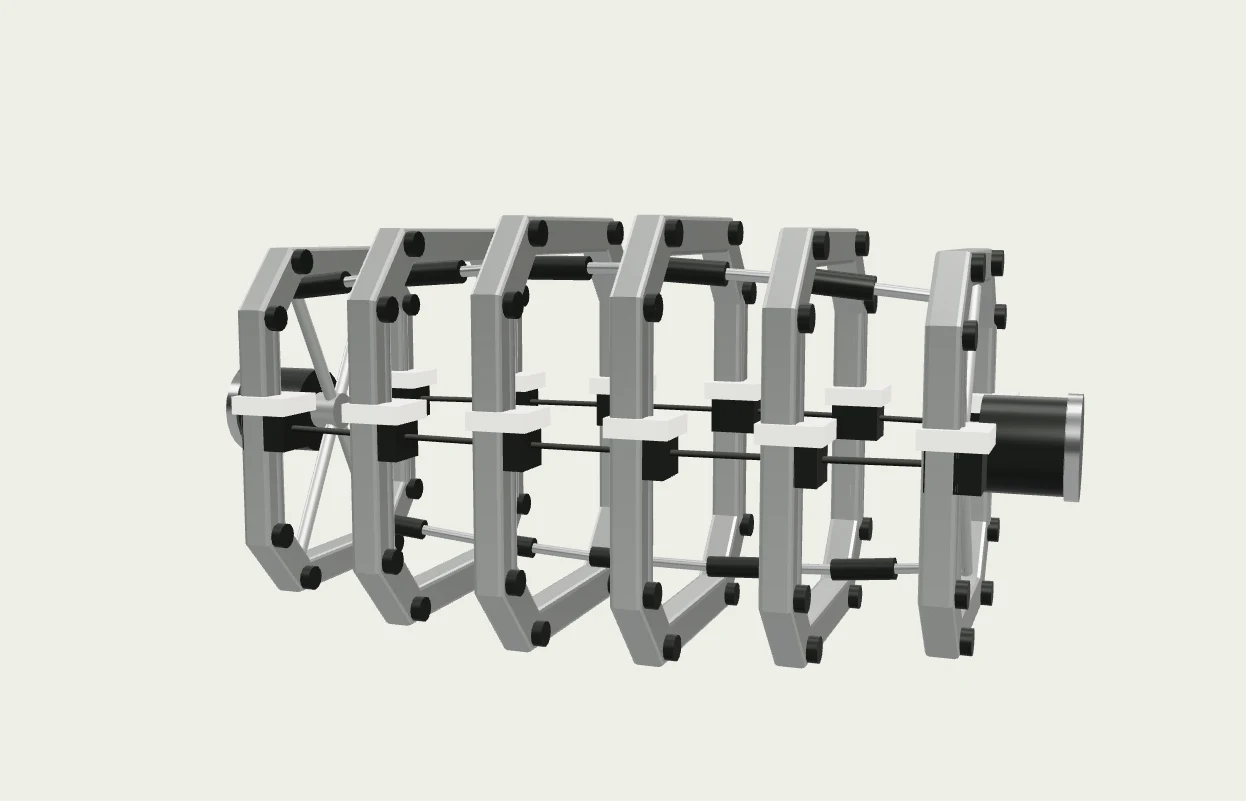
A body whose internal anchors can move. The question is whether the same outer pose could support different responses to a disturbance.

The proposition
Change the load path from within.
The test still ahead
Stable equilibrium, friction and force transmission.
Inspect Counterform
Geometric concept / Programmable compliance

Boundary loom

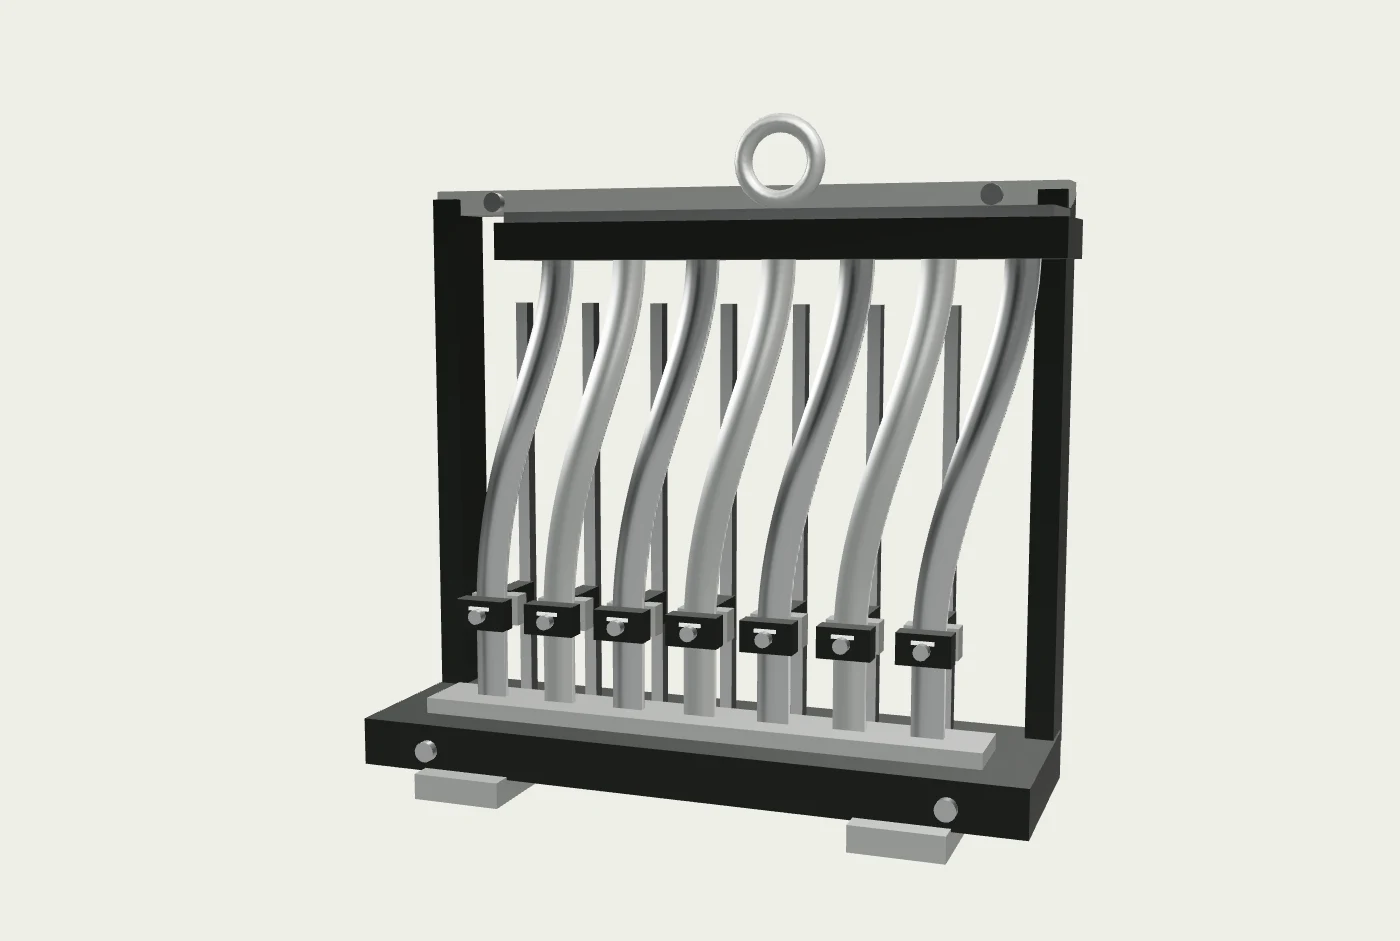
Seven continuous ribbons. A movable pattern of constraints. A study in changing how a structure yields without replacing the structure itself.

The proposition
Let the boundary define the response.
The test still ahead
Clamp slip, strain concentration and repeatability.
Inspect Boundary loom
The other half of the body

A mechanism needs
to know what matters.

Our intelligence programme connects the body to observation, prediction and the next action.

Explore Intelligence
A physical problem worth solving.

What should a robot
be able to do?